
Title: Robotic Palletizers: Efficient Solutions for Canning Industry | Premier Tech
Description:
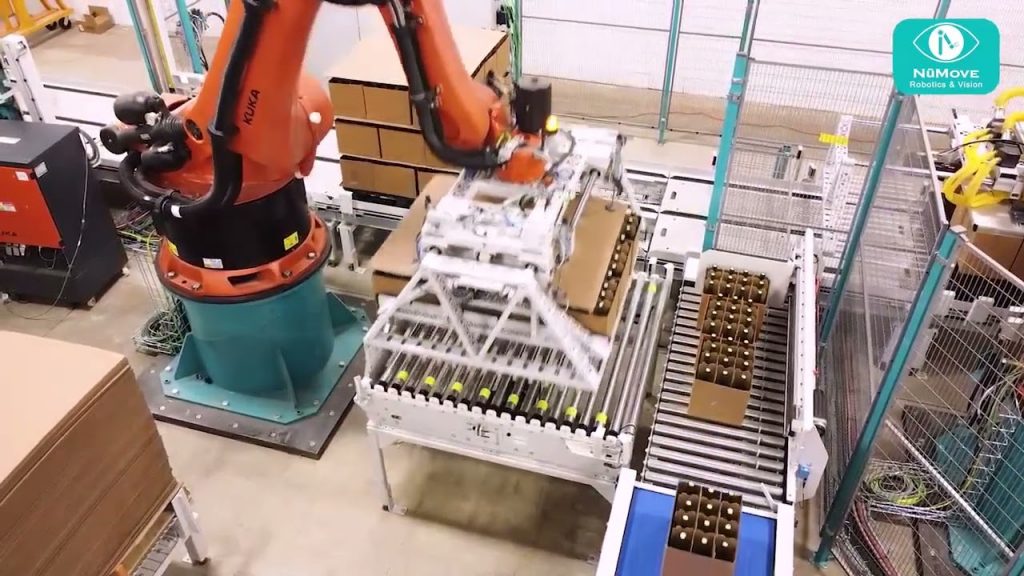
Welcome to Premier Tech’s world of Robotic Palletizers! As leading manufacturers of palletizers, we take pride in offering cutting-edge technology that meets the diverse needs of the industry. In this video, we showcase our Robotic Palletizer for Cans, featuring an innovative Magnetic Gripper, which ensures precise and secure handling of cans.
Introduction:
Discover the future of palletizing with Premier Tech’s Robotic Palletizers! In this video, we present our state-of-the-art Robotic Palletizer for Cans, equipped with a Magnetic Gripper, designed to optimize efficiency and accuracy in the canning industry. Join us as we explore the remarkable features and benefits of this advanced technology.
Video Content:
Our Robotic Palletizer for Cans is specifically engineered to enhance productivity and streamline operations in the canning industry. With its Magnetic Gripper, it offers a reliable and efficient solution for handling and stacking cans on pallets. This video provides an in-depth demonstration of the operation steps, highlighting the key points and interesting facts about our Robotic Palletizer.
Key Highlights:
– Magnetic Gripper: Our Robotic Palletizer utilizes a magnetic gripper that securely grasps and positions cans, ensuring precise placement on pallets.
– Versatility: This system can efficiently handle various can sizes and configurations, accommodating the diverse needs of canning operations.
– Speed and Accuracy: By employing advanced robotic technology, our palletizer guarantees fast and accurate palletizing, reducing manual labor and minimizing errors.
– Flexibility: The Robotic Palletizer offers customizable programming options, allowing for quick adjustments to suit different production requirements.
– Space Optimization: With its compact design, our palletizer maximizes floor space, optimizing the layout of your production facility.
Call to Action:
If you’re looking to enhance your canning operation’s efficiency and productivity, our Robotic Palletizer is the ideal solution. Don’t miss out on this game-changing technology – like, subscribe, and share this video to stay updated on the latest advancements in palletizing!
Additional Tags and Keywords:
Robotic Palletizers, Robotic Palletizer for Cans, Magnetic Gripper, Premier Tech, palletizing solutions, canning industry, automation, efficiency, advanced technology, robotic handling, precise placement, customizable programming, productivity enhancement.
Hashtags:
#RoboticPalletizers #CanningIndustry #PremierTech #Efficiency #Automation #MagneticGripper #ProductivityEnhancement
Sure! Here’s a sample code for a tilter for a Robotic Palletizer using a Magnetic Gripper:
“`python
import time
# Function to tilt the cans using the magnetic gripper
def tilt_cans():
# Code to activate the magnetic gripper
activate_magnetic_gripper()
# Code to tilt the cans
tilt_angle = 45 # Set the desired tilt angle
tilt_duration = 2 # Set the duration for which the cans should be tilted
# Code to control the tilter mechanism to tilt the cans at the desired angle for the specified duration
control_tilter(tilt_angle, tilt_duration)
# Code to deactivate the magnetic gripper
deactivate_magnetic_gripper()
# Function to activate the magnetic gripper
def activate_magnetic_gripper():
# Code to activate the magnetic gripper mechanism
print(“Magnetic gripper activated”)
# Function to control the tilter mechanism
def control_tilter(tilt_angle, tilt_duration):
# Code to control the tilter mechanism to tilt the cans at the desired angle for the specified duration
print(“Tilting cans at”, tilt_angle, “degrees for”, tilt_duration, “seconds”)
time.sleep(tilt_duration) # Simulating the tilt duration using a sleep function
# Function to deactivate the magnetic gripper
def deactivate_magnetic_gripper():
# Code to deactivate the magnetic gripper mechanism
print(“Magnetic gripper deactivated”)
# Main function to test the tilter
def main():
# Call the tilt_cans function to tilt the cans using the magnetic gripper
tilt_cans()
# Call the main function
if __name__ == “__main__”:
main()
“`
This is a basic example that demonstrates the structure and functionality of the tilter for a Robotic Palletizer using a Magnetic Gripper. You can modify and add more specific functionalities as per your requirements.Palletizerse
#Robotic #Palletizer #Cans #Magnetic #Gripper